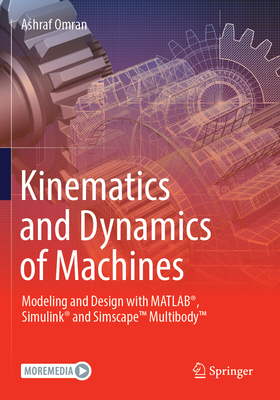
Kinematics and Dynamics of Machines: Modeling and Design with Matlab(r), Simulink(r) and Simscape(tm) Multibody(tm)
暫譯: 機器運動學與動力學:使用 Matlab、Simulink 與 Simscape Multibody 進行建模與設計
Omran, Ashraf
- 出版商: Springer
- 出版日期: 2026-09-28
- 售價: $3,940
- 貴賓價: 9.5 折 $3,743
- 語言: 英文
- 頁數: 660
- 裝訂: Quality Paper - also called trade paper
- ISBN: 3031727037
- ISBN-13: 9783031727030
-
相關分類:
動力學 Dynamics
海外代購書籍(需單獨結帳)
相關主題

商品描述
This textbook presents theory-based approaches to teaching and studying the kinematics and dynamics of machines, complemented by graphics and animations using contemporary software; MATLAB(R), Simulink(R) and Simscape(TM) Multibody(TM). Students gain hands-on experience with relevant engineering software, developing skills in modeling, analysis, simulation, and animation while learning the course material. Instructors can guide students in creating their own systems, helping them better understand and optimize their designs.
Emphasizing the ubiquity of machines, the text is informed by a wide variety of examples; it caters for the generic--such as the factory packing machine--but also draws on the more familiar--such as kitchen appliances--to highlight machines encountered in everyday life. The book provides a connection between the acquisition of marketable skills in computer modeling and study for an academic degree and has evolved from the author's teaching experience. Features of the textbook include:
- extensive use of examples in the text, covering numerical, graphical, analytical, and Simscape(TM) Multibody(TM) model-based techniques examples for students;
- end-of-chapter exercises allowing regular assessment of learning attainment;
- a pdf solutions manual for instructors adopting the book, available from SpringerLink; and
- lecture slides for use or adaptation by instructors.
Chiefly intended for an upper-level undergraduate course in the design and kinematics of machines, this textbook also contains more advanced elements that extend its relevance into the sphere of the beginning graduate student.
商品描述(中文翻譯)
本教科書介紹以理論為基礎的機器運動學與動力學教學及學習方法,並搭配使用當代軟體 MATLAB(R)、Simulink(R) 和 Simscape(TM) Multibody(TM) 所製作的圖形與動畫。學生在學習課程內容的同時,能夠實際操作相關工程軟體,培養建模、分析、模擬與動畫製作等技能。教師則可引導學生建立自己的系統,協助他們更深入理解並最佳化設計。
本書強調機器在各個領域中的普遍性,內容採用多樣化的實例:除了工廠包裝機等一般性案例,也納入廚房家電等較為熟悉的例子,以突顯日常生活中經常接觸到的機器。本書將電腦建模實務技能的培養,與學術學位的學習相互連結,內容亦源自作者的教學經驗。本教科書的特色包括:
• 大量運用實例,涵蓋數值、圖形、解析,以及以 Simscape(TM) Multibody(TM) 模型為基礎的技術,供學生學習;
• 每章章末皆附練習題,方便定期評量學習成果;
• 採用本書的教師可透過 SpringerLink 取得 PDF 解答手冊;以及
• 提供教師使用或自行修改的課堂投影片。
本教科書主要 предназнач於高年級大學部的機器設計與運動學課程,同時也包含較進階的內容,使其適用於初階研究生的學習。
作者簡介
Dr. Ashraf Omran is an Associate Professor in the Facilities Engineering Department at Massachusetts Maritime Academy (MMA) and an EP lecturer in Mechanical Engineering at Johns Hopkins University (JHU). He earned a Bachelor's degree in Aerospace Engineering from Cairo University, Egypt, in 2002. He then spent four years as a teaching and research assistant at Cairo University, where he received his Master's degree in Aerospace Engineering, focusing on the topic of "Kinematics, Dynamics, and Control of Stewart Manipulator." Following a scholarship, he earned his Ph.D. in Aerospace Engineering Science from Old Dominion University (ODU), VA, in 2010.
Shortly thereafter, he joined the Faculty of Mechanical and Aerospace Engineering at ODU to teach and work as a research scientist on enhancing the ATOS NASA Flight Simulator. He then worked at Fiat for nearly eight years, during which he registered twenty-four patents in the field of transmission control systems. Later, Dr. Omran returned to academia, teaching at Texas A&M, Loyola University in Chicago, IIT, and currently at MMA and JHU. Dr. Omran has authored dozens of papers in the fields of dynamics, robotics, and control. He has received several awards, including the 2010 Lee M. Klinefelter Faculty Award for Overall Excellence in Aerospace at ODU.
Dr. Ashraf Omran is a member of ASME and AIAA. He has served as a session chair at the American Control Conference and is a reviewer for journals such as the Journal of Guidance, Control, and Dynamics; Aerospace Science and Technology; the Journal of Dynamic Systems, Measurement and Control; Nonlinear Dynamics; the Journal of Vibration and Control; the Journal of Mechanical Engineering Science; and the Journal of Zhejiang University--SCIENCE.
作者簡介(中文翻譯)
Ashraf Omran 博士是 Massachusetts Maritime Academy (MMA) Facilities Engineering Department 的副教授,也是 Johns Hopkins University (JHU) Mechanical Engineering 的 EP 講師。他於 2002 年取得埃及 Cairo University 的航空工程學士學位。之後,他在 Cairo University 擔任教學與研究助理四年,並取得航空工程碩士學位,研究主題為「Stewart Manipulator 的運動學、動力學與控制」。獲得獎學金後,他於 2010 年取得維吉尼亞州 Old Dominion University (ODU) 的航空工程科學博士學位。
不久之後,他加入 ODU 的 Mechanical and Aerospace Engineering Faculty,負責教學,並擔任研究科學家,從事強化 ATOS NASA Flight Simulator 的研究。之後,他在 Fiat 任職將近八年,期間於變速箱控制系統領域取得 24 項專利。後來,Omran 博士重返學術界,曾在 Texas A&M、芝加哥 Loyola University 以及 IIT 任教,目前則任教於 MMA 和 JHU。Omran 博士已在動力學、機器人學與控制領域發表數十篇論文。他曾獲得多項獎項,包括 ODU 於 2010 年頒發的 Lee M. Klinefelter Faculty Award for Overall Excellence in Aerospace。
Ashraf Omran 博士是 ASME 和 AIAA 的會員。他曾擔任 American Control Conference 的場次主席,並擔任多份期刊的審稿人,包括 Journal of Guidance, Control, and Dynamics、Aerospace Science and Technology、Journal of Dynamic Systems, Measurement and Control、Nonlinear Dynamics、Journal of Vibration and Control、Journal of Mechanical Engineering Science,以及 Journal of Zhejiang University--SCIENCE。