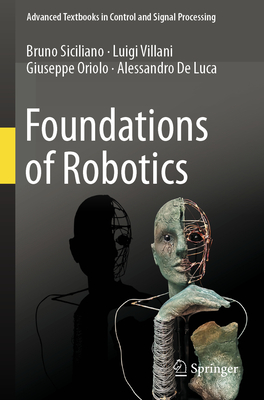
Foundations of Robotics
暫譯: 機器人學基礎
Siciliano, Bruno, Villani, Luigi, Oriolo, Giuseppe
- 出版商: Springer
- 出版日期: 2026-09-08
- 售價: $3,960
- 貴賓價: 9.5 折 $3,762
- 語言: 英文
- 頁數: 719
- 裝訂: Quality Paper - also called trade paper
- ISBN: 3031855256
- ISBN-13: 9783031855252
-
相關分類:
機器人製作 Robots
已絕版
買這商品的人也買了...
-
 Physics of Photonic Devices, 2/e (Hardcover)
$2,350$2,303 -
 Photonic Devices 2 Part Set (Paperback)
$4,390$4,170 -
 Multidimensional Signal, Image, and Video Processing and Coding, 2/e (Hardcover)
$1,380$1,352 -
 Fundamentals of Microfabrication and Nanotechnology, Volume II, 3/e (Hardcover)
$1,700$1,666 -
 Diode Lasers and Photonic Integrated Circuits, 2/e (Hardcover)
$1,890$1,852 -
 The Finite Element Method in Electromagnetics, 3/e (Hardcover)
$8,880$8,436 -
 Digital Image Processing, 4/e (GE-Paperback)
$1,390$1,362 -
 Digital Design: With an Introduction to the Verilog HDL, VHDL, and SystemVerilog, 6/e (GE-Paperback)
$1,380$1,352 -
 Fundamentals of Photonics, 2 Volume Set, 3/e (Hardcover)
$3,780$3,704 -
 $1,519電磁兼容原理與應用 -- 方法分析電路測量, 3/e (Electromagnetic Compatibility: Methods, Analysis, Circuits, and Measurement, 3/e)
-
 Feedback Control of Dynamic Systems, 8/e (IE-Paperback)
$1,380$1,352 -
 Physics of Semiconductor Devices, 4/e (Hardcover)
$1,880$1,842 -
 Digital Audio Signal Processing, 3/e (Hardcover)
$1,750$1,715 -
 數字信號處理的 FPGA 實現, 4/e
$1,188$1,128 -
 State Estimation for Robotics, 2/e (Hardcover)
$3,960$3,762 -
 Probability and Stochastic Processes: A Friendly Introduction for Electrical and Computer Engineers, 4/e (IE-Paperback)
$1,480$1,450 -
 Engineering Electromagnetics, 9/e (Paperback)
$1,750$1,715
相關主題

商品描述
This textbook explores the foundational principles of robotics, focusing on its core pillars: modeling, planning, and control. Balancing mathematical rigor and physical intuition, a coherent formalism is established and used throughout the book. At the same time, technological challenges and application-driven solutions are given appropriate consideration.
With a general perspective that includes both fixed-base manipulators and mobile robots, the book presents the essential tools for understanding key topics such as kinematics, statics, trajectory planning, dynamics, and motion control. In its second part, more advanced topics are addressed, including wheeled robots, visual control, motion planning, force control, flexible robots and cooperative manipulation.
To support the learning process, appendices provide essential background material on linear algebra, mechanics, differential geometry, control theory, and graph search algorithms. The practical implementation of the methodologies is emphasized throughout, with over 50 worked examples and case studies, many supported by simulations. Additionally, more than 190 end-of-chapter problems are included, with a Solutions Manual available for instructors adopting the book for their courses.
Foundations of Robotics is designed for use as a textbook in both undergraduate and graduate robotics courses within engineering programs, making it an ideal resource for students and educators alike.
A list of errata for this book can be found at https: //drive.google.com/file/d/1dwZ6LvN4hf2lfE4CGft3HtCI54Ga6xq9
本教科書探討機器人學的基礎原理,著重於其核心支柱:建模(modeling)、規劃(planning)與控制(control)。本書在數學嚴謹性與物理直覺之間取得平衡,建立一套連貫的形式化架構,並貫穿全書加以運用。同時,也適度考量技術挑戰與由應用需求驅動的解決方案。
本書採取涵蓋固定基座機械手臂與移動機器人的整體觀點,介紹理解運動學(kinematics)、靜力學(statics)、軌跡規劃(trajectory planning)、動力學(dynamics)及運動控制(motion control)等重要主題所需的基本工具。在第二部分中,進一步探討較進階的主題,包括輪式機器人、視覺控制(visual control)、運動規劃(motion planning)、力控制(force control)、柔性機器人,以及協同操作(cooperative manipulation)。
為支援學習過程,本書附錄提供線性代數、力學、微分幾何、控制理論及圖搜尋演算法等必要的背景資料。全書強調方法的實務實作,包含 50 多個完整解說的範例與案例研究,其中許多搭配模擬進行說明。此外,每章末附有超過 190 道習題;對於採用本書作為課程教材的教師,另提供習題解答手冊(Solutions Manual)。
《Foundations of Robotics》適合作為工程學系大學部與研究所機器人學課程的教科書,是學生與教育工作者的理想參考資源。
本書的勘誤表可於以下網址取得:
https://drive.google.com/file/d/1dwZ6LvN4hf2lfE4CGft3HtCI54Ga6xq9