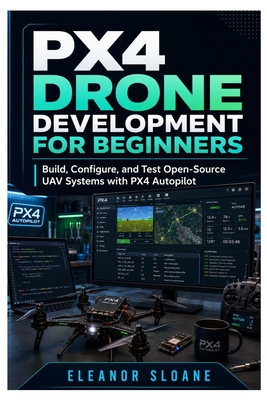
PX4 Drone Development for Beginners: Build, Configure, and Test Open-Source UAV Systems with PX4 Autopilot
暫譯: PX4 無人機開發入門:使用 PX4 自動駕駛儀構建、配置和測試開源 UAV 系統
Sloane, Eleanor
- 出版商: Independently Published
- 出版日期: 2026-07-20
- 售價: $940
- 貴賓價: 9.5 折 $893
- 語言: 英文
- 頁數: 216
- 裝訂: Quality Paper - also called trade paper
- ISBN: 9798188153311
- ISBN-13: 9798188153311
-
相關分類:
無人機
海外代購書籍(需單獨結帳)
相關主題

商品描述
A modern drone is more than a frame, motors, and a flight controller. It is a coordinated system in which sensors measure movement, estimators calculate the aircraft's condition, controllers produce corrections, actuators create motion, and communication tools connect the vehicle to pilots, developers, and external applications.
PX4 Drone Development for Beginners provides a practical introduction to building and developing open-source unmanned vehicle systems with PX4 Autopilot.
Rather than treating PX4 as a collection of settings inside a ground-control application, this guide explains it as a complete development platform. You will learn how the hardware, firmware, simulation environment, communication protocols, programming interfaces, safety systems, and testing procedures work together.
The book begins with PX4-compatible hardware and basic vehicle configuration before progressing into source-code builds, simulation, autonomous missions, Python control, ROS 2 integration, custom firmware modules, tuning, logging, debugging, and controlled hardware deployment.
Inside this project-based guide, you will learn how to:
- Understand PX4, Dronecode, Pixhawk hardware standards, MAVLink, MAVSDK, QGroundControl, and ROS 2
- Distinguish the flight controller, firmware, simulator, ground station, companion computer, sensors, and actuators
- Design a dependable beginner PX4 development platform
- Select a supported flight controller for multicopters, fixed-wing aircraft, VTOL vehicles, or rovers
- Match motors, electronic speed controllers, propellers, batteries, and power modules correctly
- Plan telemetry, radio-control, GNSS, CAN, serial, USB, and companion-computer connections
- Prepare a PX4 development environment on Ubuntu, Windows through WSL2, or macOS
- Clone the PX4-Autopilot source repository and manage Git submodules
- Build PX4 for simulation and supported flight-controller hardware
- Install firmware and configure a vehicle with QGroundControl
- Select an airframe and preserve a known-good configuration
Practical exercises guide you through cloning and building PX4, configuring a vehicle on the bench, running an autonomous survey-style simulation, investigating parameters and uORB topics, controlling a simulated aircraft with Python, connecting ROS 2, writing a custom vehicle-state monitor, and diagnosing simulated faults.
The final capstone brings the entire workflow together: selecting the hardware, configuring the aircraft, programming its supporting applications, validating its behaviour, reviewing logs, and preparing the system for controlled deployment.
Appendices provide essential PX4 commands, troubleshooting references, simulation and bench checklists, first-hover procedures, mission checklists, version records, parameter-change logs, test-report templates, and fault-correction records.
Whether you are a drone builder, software developer, robotics student, UAV researcher, operator, technician, or hardware integrator, this book will help you move beyond basic configuration and understand how PX4 systems are developed and validated.
Build the system. Test it in simulation. Verify every configuration. Move to hardware only when the results are understood.
商品描述(中文翻譯)
自信地構建、配置、編程和測試 PX4 驅動的無人機系統
現代無人機不僅僅是框架、馬達和飛行控制器。它是一個協調的系統,其中傳感器測量運動,估算器計算飛行器的狀態,控制器產生修正,執行器創造運動,通信工具將飛行器連接到飛行員、開發者和外部應用程序。
PX4 無人機開發入門提供了一個實用的介紹,幫助您使用 PX4 自動駕駛儀構建和開發開源無人駕駛系統。
本指南不僅將 PX4 視為地面控制應用程序中的一組設置,而是將其解釋為一個完整的開發平台。您將學習硬體、韌體、模擬環境、通信協議、編程介面、安全系統和測試程序如何協同工作。
本書從 PX4 兼容的硬體和基本的飛行器配置開始,然後進入源代碼構建、模擬、自主任務、Python 控制、ROS 2 集成、自定義韌體模塊、調整、日誌記錄、除錯和受控硬體部署。
在這本基於項目的指南中,您將學習如何:
- 理解 PX4、Dronecode、Pixhawk 硬體標準、MAVLink、MAVSDK、QGroundControl 和 ROS 2
- 區分飛行控制器、韌體、模擬器、地面站、伴隨計算機、傳感器和執行器
- 設計一個可靠的初學者 PX4 開發平台
- 為多旋翼、固定翼飛機、垂直起降(VTOL)飛行器或巡航車選擇支持的飛行控制器
- 正確匹配馬達、電子速度控制器、螺旋槳、電池和電源模塊
- 規劃遙測、無線控制、GNSS、CAN、串行、USB 和伴隨計算機的連接
- 在 Ubuntu、通過 WSL2 的 Windows 或 macOS 上準備 PX4 開發環境
- 克隆 PX4-Autopilot 源代碼庫並管理 Git 子模塊
- 為模擬和支持的飛行控制器硬體構建 PX4
- 安裝韌體並使用 QGroundControl 配置飛行器
- 選擇一個機架並保留已知良好的配置
實踐練習將指導您克隆和構建 PX4,在工作台上配置飛行器,運行自主調查風格的模擬,調查參數和 uORB 主題,使用 Python 控制模擬飛行器,連接 ROS 2,編寫自定義飛行器狀態監控器,並診斷模擬故障。
最後的綜合項目將整個工作流程整合在一起:選擇硬體、配置飛行器、編程其支持的應用程序、驗證其行為、檢查日誌,並為受控部署準備系統。
附錄提供了基本的 PX4 命令、故障排除參考、模擬和工作檢查清單、首次懸停程序、任務檢查清單、版本記錄、參數變更日誌、測試報告模板和故障修正記錄。
無論您是無人機建造者、軟體開發者、機器人學生、無人機研究者、操作員、技術人員或硬體整合者,本書將幫助您超越基本配置,理解 PX4 系統是如何開發和驗證的。
構建系統。在模擬中測試它。驗證每個配置。只有在理解結果後才轉向硬體。